Demonstrate and validate adaptive driving beams without an OEM camera or ECU.
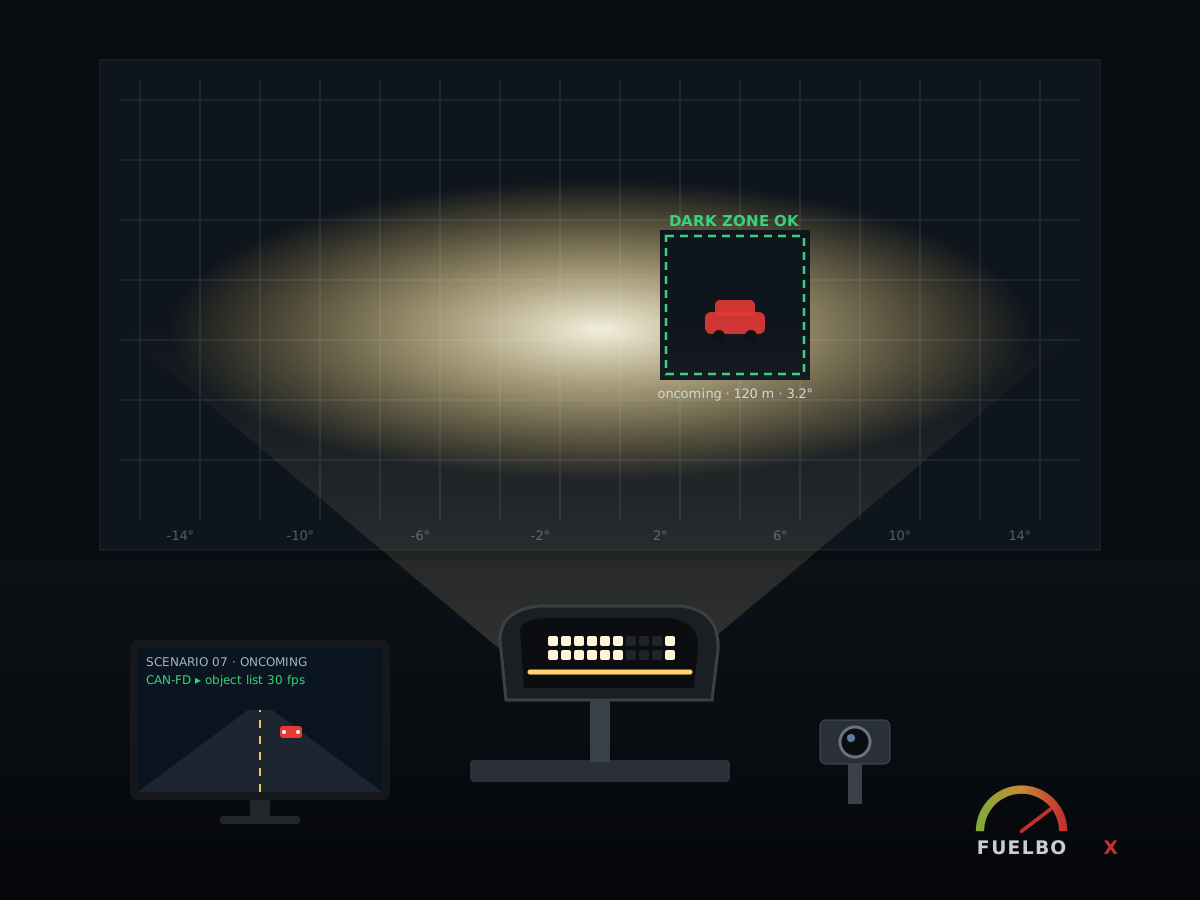
Plays night-driving scenarios, sends the object list to the ADB headlamp over CAN-FD and judges the measured dark zone on an angle-calibrated wall automatically.
Validating adaptive driving beams on real roads is slow and hard to repeat. The simulator runs the same scenario frame for frame, as often as needed, inside a dark room, so every software release can be checked against the same library.
Built for development and for demos
Development teams get a regression report per scenario. Sales and OEM reviews get a live split screen of the road scene and the real beam, with scenarios picked from a tablet.
Interactive
Watch the dark zone follow the car
ANGLE-GRID WALL · MEASUREMENT CAMERA
DARK ZONE OK
Scenario: two oncoming + one preceding vehicle
How it works
01
Scenario PC
Plays the scenario and acts as the OEM camera and vehicle.
02
CAN-FD interface
Sends object list, speed and steering to the lamp.
03
ADB lamp
Its own controller switches pixels off around each vehicle.
04
Measurement camera
Films the beam on the angle-calibrated wall.
05
Compare & report
Measured dark zone vs expected → PASS / FAIL, report per scenario.
Configurations
Core rig — camera-free
The scenario PC plays the role of the OEM camera and vehicle ECU.
Lamp features, pixel logic and performance shown on their own
No dependency on OEM parts or timing
Best for demos, development and regression after each SW release
Optional — with real OEM camera + ECU
Checks the full vehicle chain end to end.
Real camera watches the scene in a camera box with collimating lens
Same scenarios and measurement as the core rig
Nothing from the core rig is thrown away
Specifications
Scenario format
OpenSCENARIO + OpenDRIVE
Engine
CARLA / esmini based, GPU rendering, ground truth per frame
Stimulus
Virtual camera object list and vehicle signals on CAN-FD
Measurement
Dark room, angle-grid wall, synced measurement camera; option: imaging photometer